IceDrone Documentation
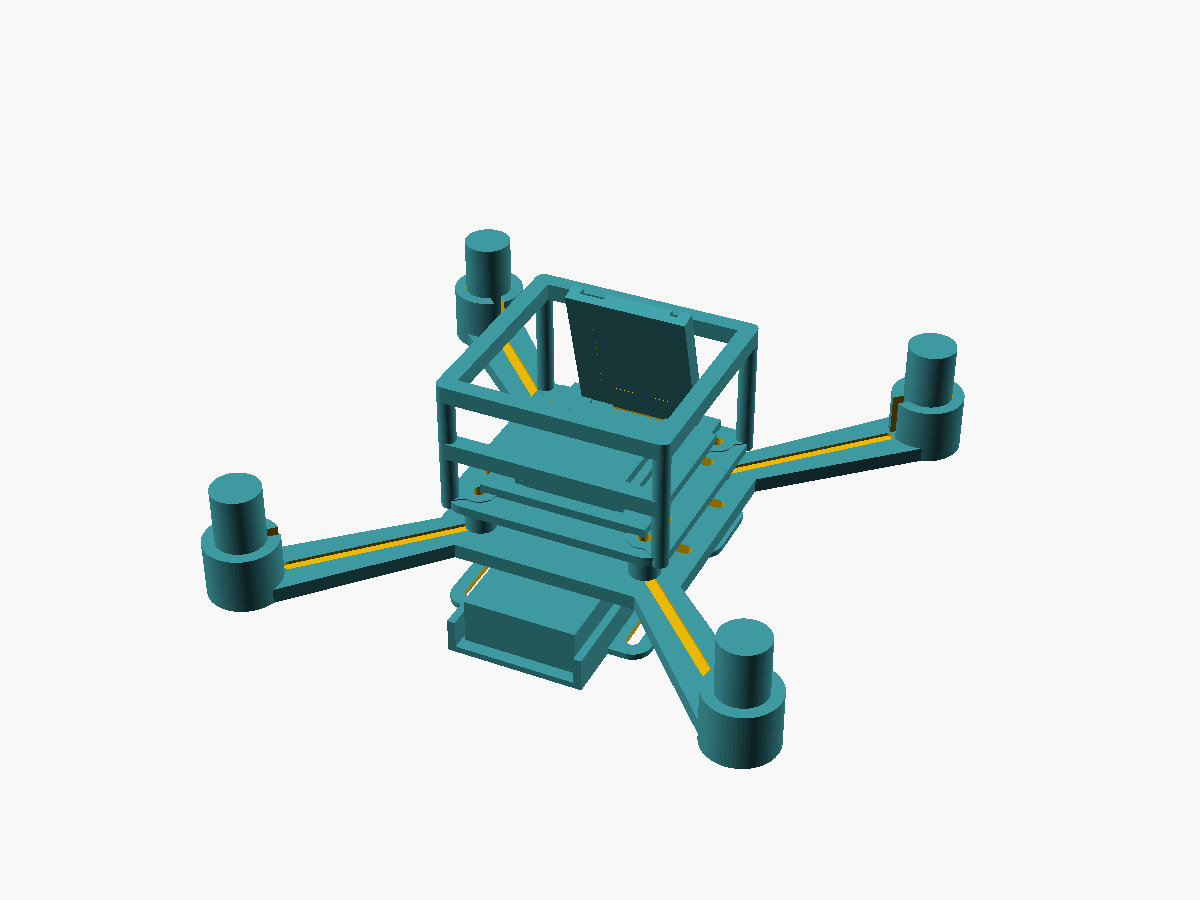
IceDrone is a small, 3D-printable brushed quadcopter built around the Seeed Studio XIAO ESP32-S3 Sense, GY-91 IMU, VL6180X ToF sensor, 8520 motors and the current Airframe V2 mechanical stack.
This documentation belongs to github.com/icepaule/IceDrone and is also published at icepaule.github.io/IceDrone.
Table of contents
| # | Chapter | Covers |
|---|---|---|
| 01 | Bill of Materials | Current V3.4 parts and electrical requirements |
| 02 | Electrical | V3.4 power architecture, motor stages, pin map, sensors |
| 03 | Mechanical | Airframe V2, printable parts, STL/SCAD, Kobra S1 settings, CG |
| 04 | Firmware | Open32Drone strategy, build settings, video/MAVLink design rules |
| 05 | Build and Test | Step-by-step assembly and bring-up |
| 06 | First Flight | Test environment, hop/hover phases, acceptance criteria |
| 07 | Safety and Legal (DE/EU) | Workshop safety and UAS legal notes |
| 08 | Troubleshooting | Common faults and causes |
| 09 | Amazon.de Order List (DE) | Dated marketplace shopping aid |
| 10 | Perfboard V3.4 soldering (DE) | Hole-by-hole solder map, SMD practice, multimeter gates |
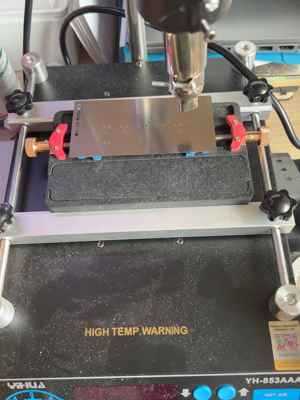
| 11 | PCB-Reflow Sn42Bi58 (DE) | Stencil, paste printing, YIHUA YH-853AAA profile, inspection |
| — | Reflow Quick Card | Condensed workbench checklist |
| — | Sources | Upstream projects and references |
Current project status
| Area | Status |
|---|---|
| Electrical revision | V3.4 HW-VERIFIED is authoritative; V3.2/V3.3 are obsolete for soldering |
| Perfboard prototype | 70×30 mm V3.4 layout and detailed solder guide available |
| Custom PCB | 70×30 mm PCB and stencil received; manual first-article assembly/reflow procedure documented |
| Reflow process | Sn42Bi58 low-temperature workflow for YIHUA YH-853AAA documented; separate bom/reflow_bom.csv available |
| Bill of materials | Updated for SS34-class motor flyback, 10 V bulk capacitors and regulated XIAO 5 V supply |
| Mechanical | Airframe V2 current; parametric OpenSCAD + STL + previews in cad/airframe_v2/ |
| Propeller CAD | Standard and experimental toroidal models in cad/propellers/ |
| Bench-test firmware | Available in firmware/bench_test/; V3.4 motor map uses GPIO4/44/6/5 |
| Camera Wi-Fi diagnostic | firmware/camera_wifi_test/ streams MJPEG over the existing Wi-Fi LAN |
| Flight-critical firmware | Tracks upstream Open32Drone; motor mapping/rotation, IMU calibration and battery calibration still require full hardware bring-up |
V3.4 electrical highlights
- M1 GPIO4/D3
- M2 GPIO44/D7
- M3 GPIO6/D5
- M4 GPIO5/D4
- I2C SDA GPIO2/D1, SCL GPIO43/D6; firmware must call
Wire.begin(2, 43) - D1-D4 = SS34-class ≥3 A Schottky
- C1 = 470 µF / 10 V low-ESR
- C2 = 100 µF / 10 V low-ESR
- raw LiHV is not connected directly to XIAO 5V/BAT; use 1S→5 V boost + D5
- photographed VL6180X order: VIN, 2V8, GND, GPIO, SHDN, SCL, SDA
Related files
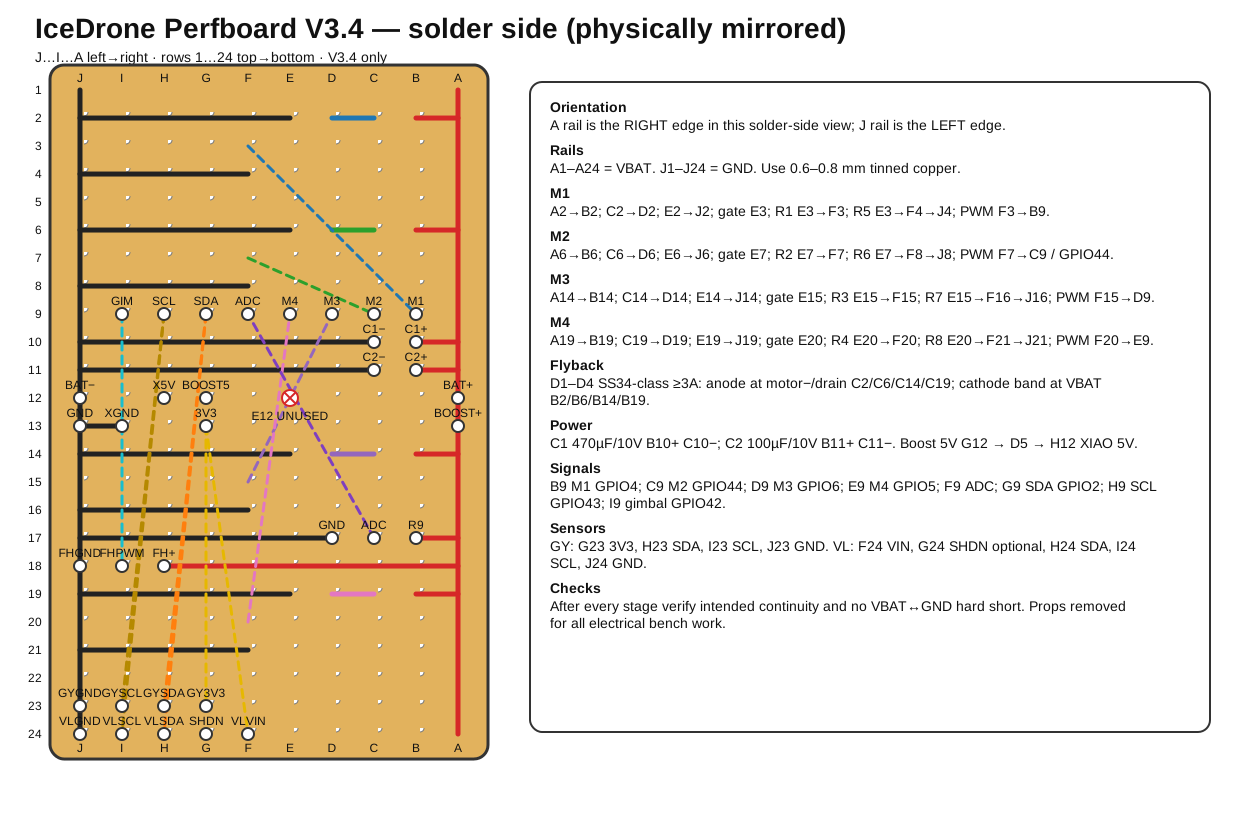
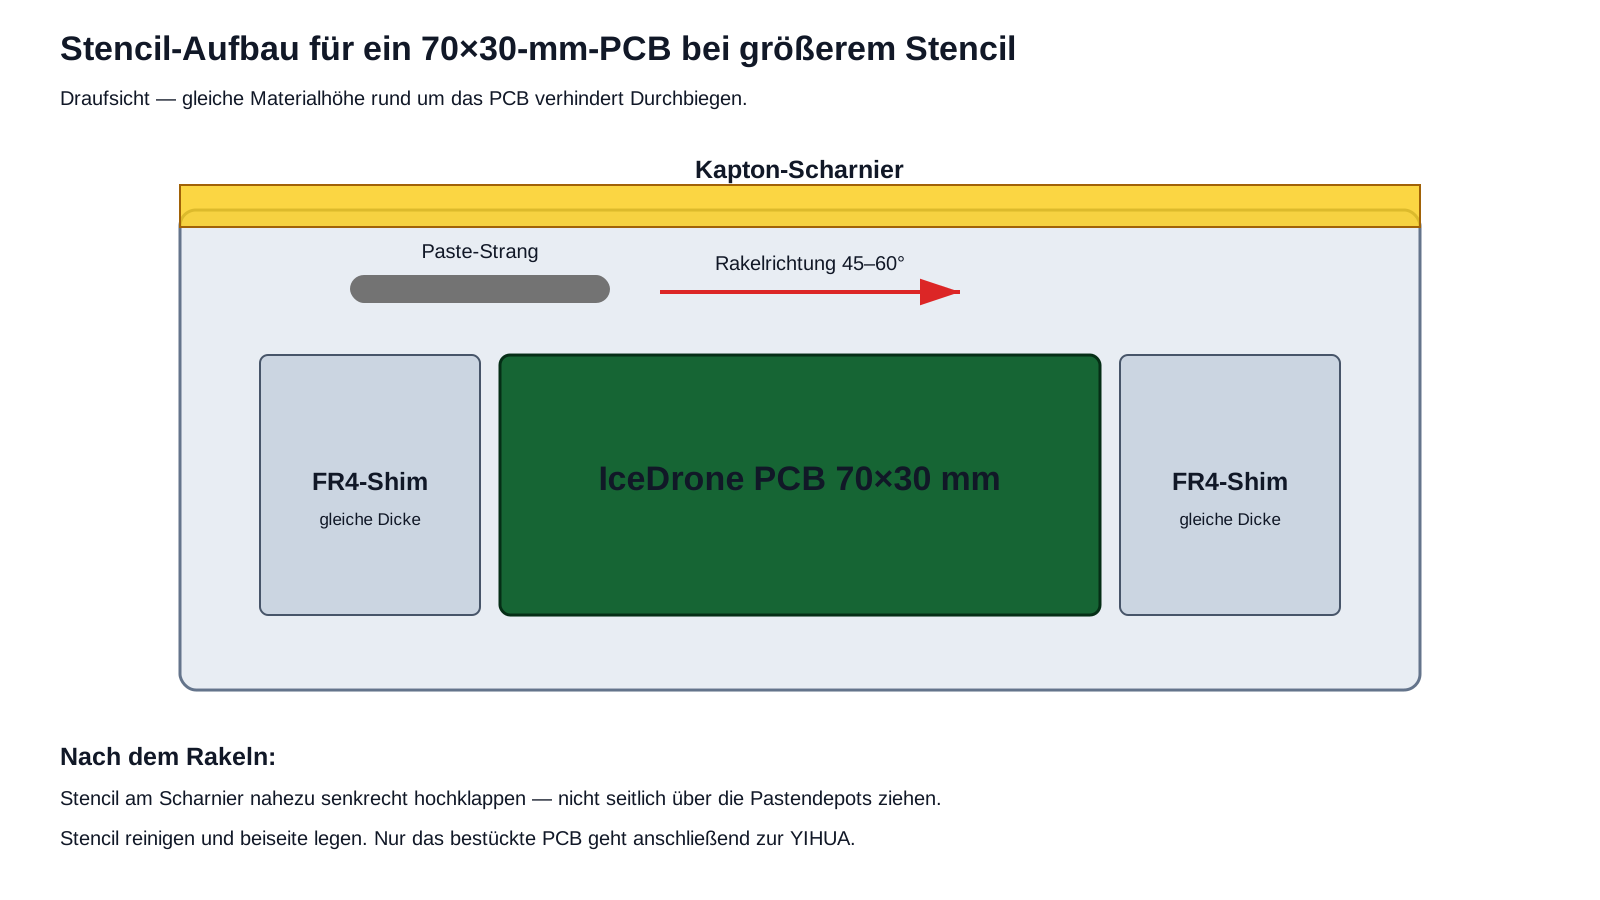
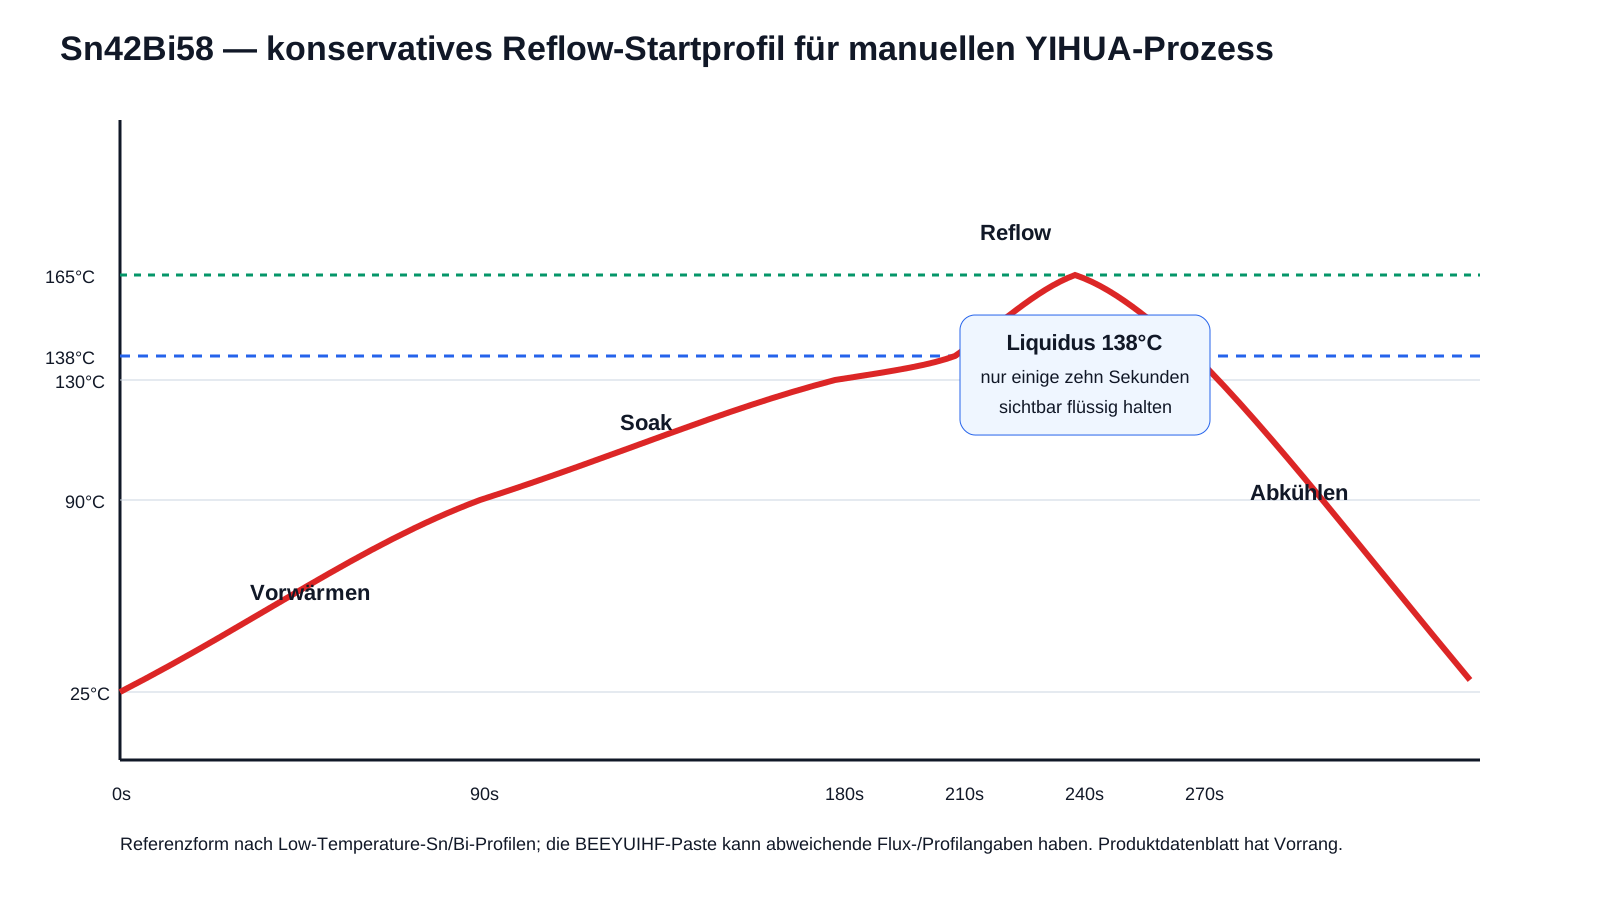
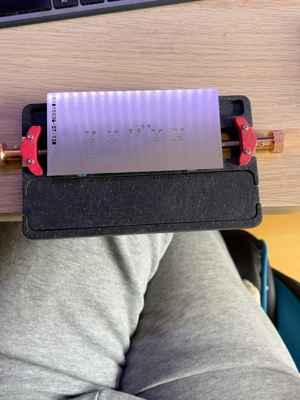
../hardware/perfboard_v34_netlist.csv— authoritative perfboard connections../hardware/perfboard_v34_pin_matrix.csv— V3.4 external pin mapassets/perfboard_v34_solder_side.svg— physically mirrored rear-view solder map../hardware/pinmap.csv— XIAO/GPIO mapping../hardware/motor_stage_netlist.csv— motor/power component netlist../bom/reflow_bom.csv— tools/consumables for stencil + Sn42Bi58 reflowassets/stencil_setup_v34.svg— oversized-stencil setupassets/reflow_profile_sn42bi58.svg— low-temperature profile referenceassets/reflow_real_stencil_fixture_v34.jpg— real stencil/clamping setupassets/reflow_real_yihua_setup_v34.jpg— real YIHUA setup / mechanical fit reference../firmware/bench_test/— pre-flight bench firmware../cad/airframe_v2/— current airframe CAD../LICENSE,../NOTICE— licensing